relay / physical intelligence
CAPTURE. SIMULATE. EXPLORE.

REAL → SIM → PHYSICAL

From the real world,
into motion.

Start with a human demonstration.
Explore what a robot can do.
A workbench for the space in between.

01 / OBSERVE THE REAL WORLDCAMERA + VOICE

Show how it’s done.

Record a guided task with your camera. Track body and hands, confirm each placement, and save the video with its evidence.

ON-DEVICE LANDMARKSCLEF CHECKPOINTSLIVE VOICE
Open collection studio ↗
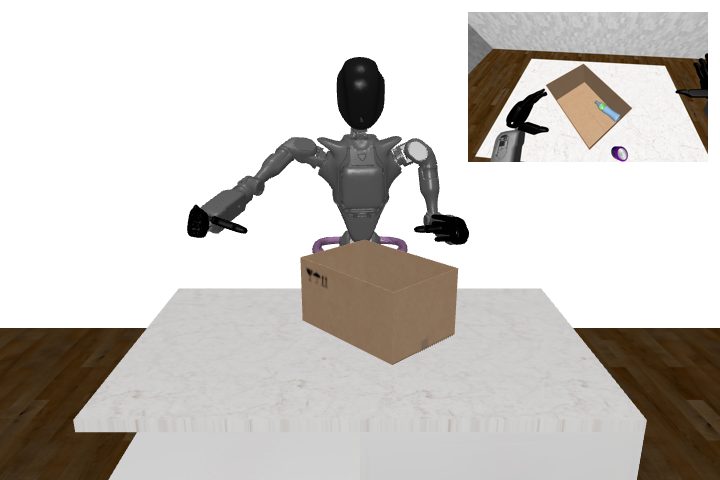
02 / GIVE THE ROBOT A TASKGR00T N1.6 · 3B
Fourier GR-1 after placing a water bottle into a cardboard box in simulationRECORDED POLICY ROLLOUT / SEED 44

Let a policy try.

Give a Fourier GR-1 an instruction. Watch NVIDIA’s learned policy act in simulation, orbit the scene, and replay every attempt.

REAL LEARNED POLICYMODAL L40SLIVE SIMULATION
Open robot console ↗
03 / EXPLORE THE VIDEO LIBRARYEvery move. Ready to find.Browse human demonstrations and robot rollouts.
Search, filter, and play the shared archive.
↗
↳

Two independent demos, one shared question: how does an observation become an action?The human recordings are not used to train or control this robot policy.

OPEN DEMOS · NO LOGIN REQUIRED

GR00T N1.6 / RECORDED SIMULATION

“Put the water bottle into the cardboard box.” · Seed 44 · Unmodified learned policy.